Machine parameter identification
Under locked rotor condition and using DC excitation method, average Ld, Lq value was obtained
Combining both electromagnetic torque and reluctance torque
IPMSG control algorithm was based on d-q rotating frame. Due to the difference between d and q axis inductance, the q-axis current controls electromagnetic torque component while d-axis current controls reluctance torque component.
Explore the source material.
Video link supplied with the project description; not independently reviewed for technical performance.
Project description and outcomes are self-reported in the supplied project description. Linked video material is provided as a source reference, not independent verification or a customer endorsement.
Connected expertise.
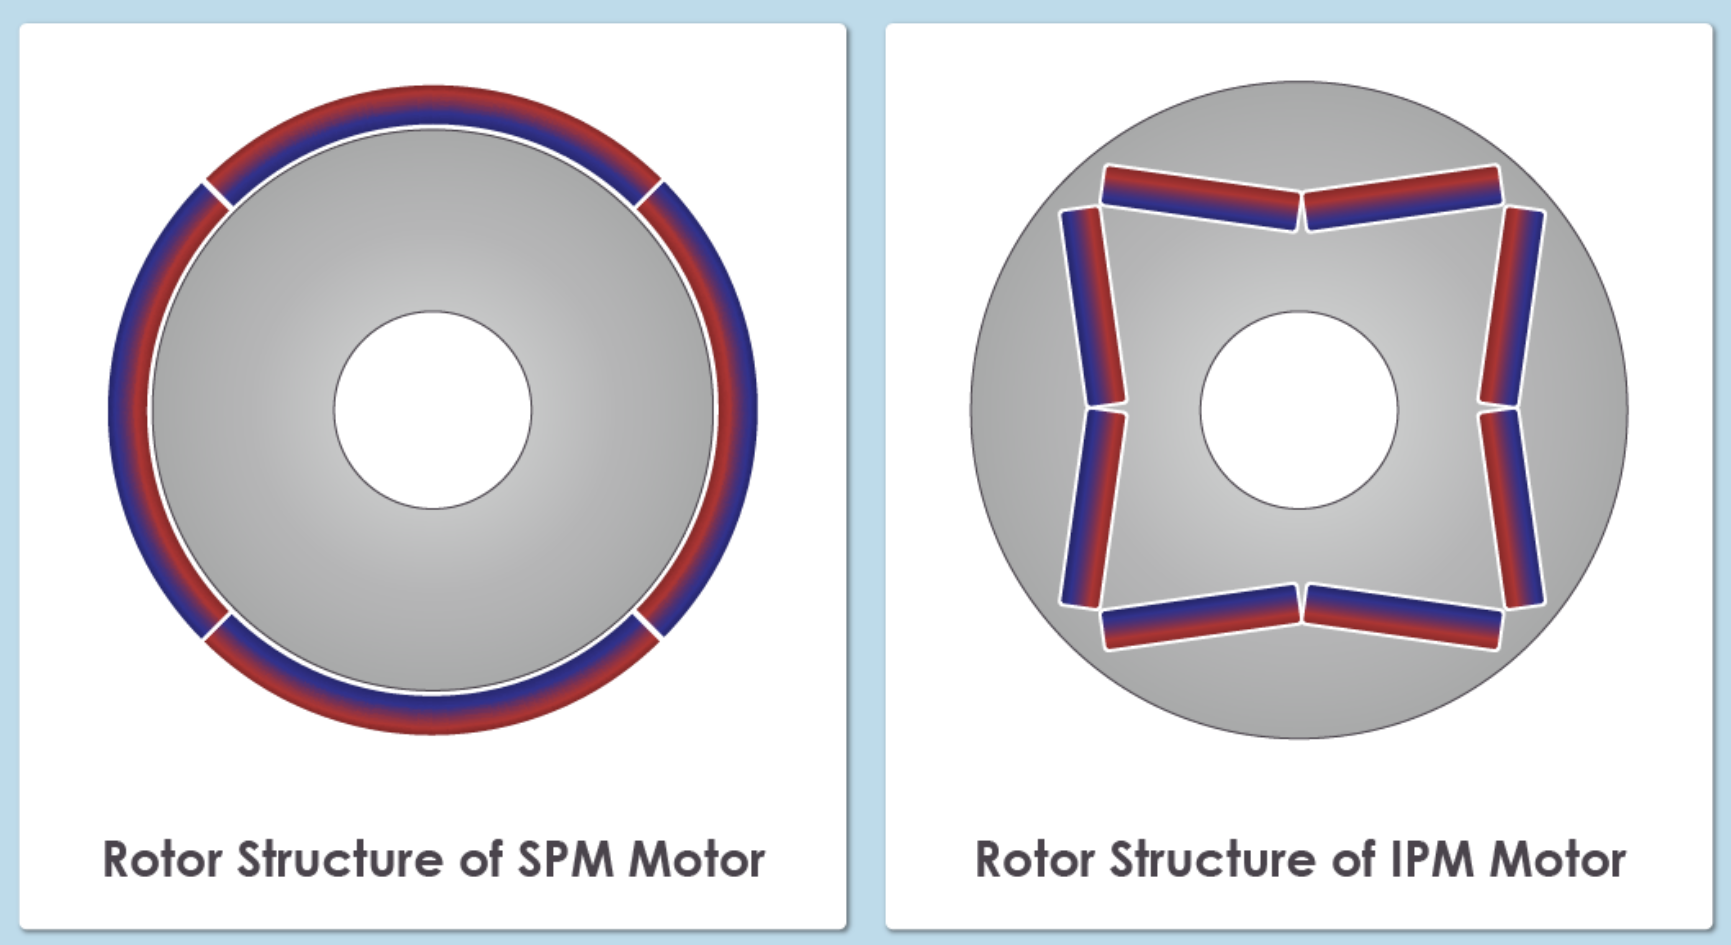
SPM and IPM rotor structures · supplied document
Motor models built for control development.
Develop linear and nonlinear electric machine models from finite-element data or an initial machine description.
Explore →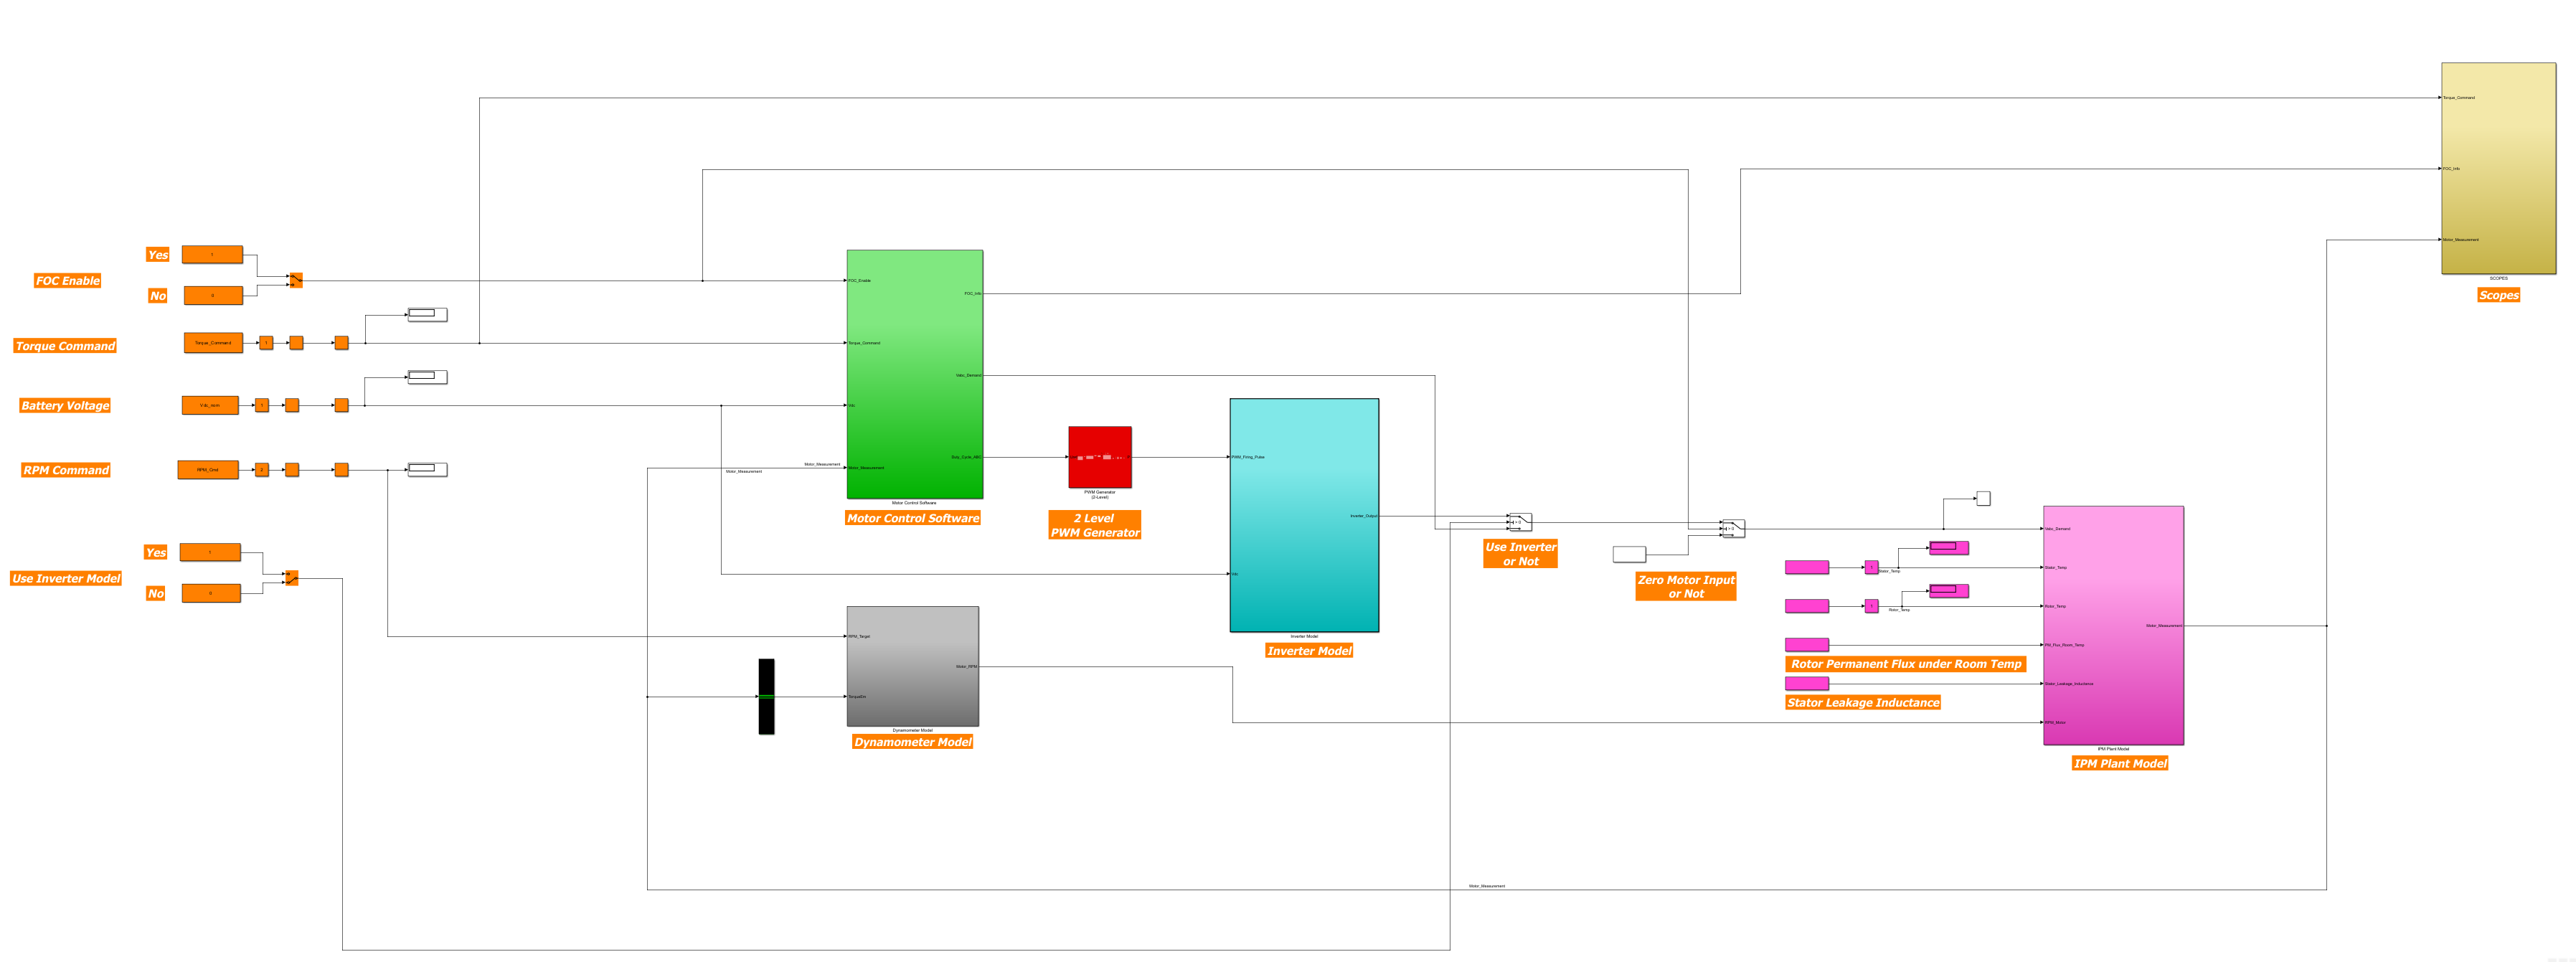
Offline propulsion simulation model · supplied document
Practical training in motor models and control.
Online tutorials connecting machine modeling, field-oriented control, real-time testing and dynamometer instrumentation.
Explore →Bring us your challenge.
Start with your application, constraints and the decision you need to make.